Servo Motor Magnets Company Explains What to Look for in High-Performance Magnets
2026-11-16
Every servo motor designer has faced a magnet that looks great on a data sheet but fails under real operating conditions. That gap between specified values and field performance is exactly what DAWA helps engineers close. In this guide, we cut through the datasheet noise and highlight the practical criteria—thermal stability, coating integrity, and magnetic consistency—that define a truly high-performance servo motor magnet.
Magnetic Stability Under Heat and Load
Heat does more than just warm a magnet—it rearranges the magnetic domains from within. As temperature climbs, thermal agitation fights against the aligned spins, gradually eroding the net field. For most neodymium grades this degradation starts well before the listed maximum operating temperature, so even brief exposure near the limit can cause irreversible losses if the load line is not carefully matched.
Mechanical stress adds a second layer of complexity. Compression or tension can shift domain walls, and when combined with elevated temperature, the effect is rarely linear. A magnet that holds its field at room temperature under a modest load may lose several percent of its flux after cycling through both heat and pressure. Designing for true stability means testing the exact grade, shape, and loading condition together—not relying on datasheet values alone.
Coating Integrity in Harsh Environments
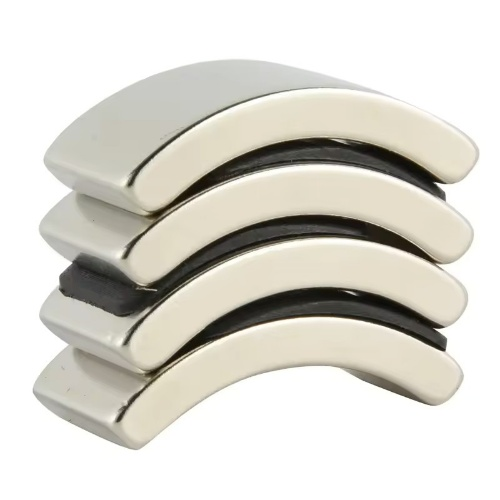
A coating that holds up in a controlled lab often tells a different story once it faces salt spray, chemical splash, or the freeze-thaw cycles of a northern industrial site. Tiny breaches start at edges, welds, or scratched spots where surface prep was less than perfect. From there, moisture wicks beneath the film, triggering rust blooms that lift the coating away in sheets. On offshore platforms, coating failure isn't just cosmetic—it accelerates steel loss and forces unplanned shutdowns for repair.
Maintaining integrity under such punishment depends less on a single miracle product and more on a chain of decisions made before the first coat is applied. Surface profile, cleanliness, and ambient conditions during application dictate whether a coating bonds or merely sits on top. Too often, the drive to finish a job fast overrides the need for dry, contaminant-free steel. Field tests reveal that even high-end epoxies and polyurethanes underperform when applied over flash rust or in high humidity, leading to microcracking and premature delamination within a few years.
Newer approaches borrow from biology rather than pure barrier technology. Self-healing additives, microencapsulated corrosion inhibitors, and flexible ceramic fillers let a coating absorb stress and seal small defects before they spread. On top of that, smarter inspection schedules—using drones with thermal imaging or ultrasonic sensors—catch early signs of blistering or adhesion loss long before visible rust appears. The goal isn't a perfect coating that never degrades, but one that fails gracefully and gives operators time to act.
Magnetic Field Consistency Across the Rotor
Rotor magnetic field consistency rarely shows up on a spec sheet, yet it quietly dictates how smoothly a motor delivers torque. In practical terms, this means every pole on the rotor should produce nearly identical flux density as it sweeps past the stator. Small variations—caused by uneven magnet magnetization, slight lamination asymmetries, or inconsistent air gap—translate directly into torque ripple and unwanted vibration. Engineers often chase this by measuring flux maps at multiple angular positions and comparing them against an ideal sinusoidal distribution, not just a single averaged value.
One overlooked culprit is residual stress from rotor manufacturing. Even when magnets are sourced from the same batch, pressing them into a laminated core can introduce mechanical strain that alters local magnetic properties. Likewise, rotor eccentricity—where the geometric center doesn't align with the rotational axis—creates a periodic flux imbalance that grows worse under thermal expansion. A robust approach involves back-EMF harmonic analysis: if the third or fifth harmonic starts climbing beyond a few percent of the fundamental, the rotor likely has a spatial inconsistency rather than a simple control tuning issue.
Improving consistency isn't just about tighter tolerances; it's also about design choices that make the system less sensitive to unavoidable variance. Skewing the rotor stack by a fraction of a slot pitch, for instance, averages out local flux irregularities and reduces cogging without expensive post-processing. Similarly, using segmented magnets with individually matched flux values can compensate for a slightly non-uniform air gap. In the end, a rotor with truly consistent magnetic behavior lets the drive run quieter, last longer, and respond more predictably across speed and load ranges.
Tolerance Control for Air Gap Precision
Maintaining a precise air gap in magnetic assemblies is less about hitting a single number and more about managing the accumulation of tiny deviations across every mating surface. Each component carries its own tolerance band, and when stacked together, these variances can quietly eat away at the intended gap. The real challenge lies in deciding where to tighten control and where to let natural variation run free—over-constraining every dimension drives cost and lead time without meaningful gains, while under-constraining invites performance drift.
A practical approach starts with a tolerance stack-up that treats the air gap as a derived dimension, not an isolated one. By mapping how flatness, parallelism, and thickness errors propagate through the stack, engineers can identify the few contributors that dominate the final gap. Often, swapping a single machined spacer for a selectively fitted shim or introducing a controlled lapping step yields tighter gap control than chasing microns on every part. The goal is to make the process robust, so the gap falls within spec even when incoming parts sit at the edges of their tolerance zones.
Beyond the math, careful attention to measurement and assembly sequence closes the loop. In-process checks with non-contact sensors can flag drift before it becomes a scrap event, while fixture design that mimics real mounting conditions prevents surprises after final assembly. Documenting the relationship between gap variation and functional performance—whether it is holding force, torque ripple, or acoustic noise—helps teams spend their tolerance budget where it actually matters, rather than chasing perfection for its own sake.
Demagnetization Resistance Over Time
A magnet’s ability to hold its charge over months and years rarely gets attention until something drifts out of spec. In practice, modern NdFeB grades with high intrinsic coercivity can sit on a shelf for a decade and lose less than a fraction of a percent of their original flux, provided they are not pushed past their working temperature or exposed to strong opposing fields. The real story is not whether demagnetization happens, but how flat the curve stays under ordinary conditions.
What tends to accelerate long-term loss is less obvious: repeated thermal cycling, mechanical shock, or even a poorly chosen coating that allows hydrogen to creep into the grain boundary. Once that starts, the decline can be gradual, almost invisible in spot checks, then show up as a sudden drop when the magnet is finally asked to perform near its rated limit. That is why serious buyers test after accelerated aging rather than trusting the initial pull force.
Material Grade Choices Beyond the Datasheet
A datasheet rarely tells you how a material behaves after three years in a humid, vibrating assembly. The tensile and yield figures listed there are usually generated from polished test bars under tightly controlled conditions, not from castings or weldments with real-world stress concentrations. When choosing between two seemingly equivalent grades, the more useful question is often: how does each one handle your actual manufacturing route and service environment? Trace elements that never appear in the standard chemical composition ranges can shift fatigue life or corrosion resistance enough to matter, and these effects show up in mill test reports or long-term field data far more reliably than in a marketing table.
Grade selection also has a hidden commercial dimension. A material with slightly lower advertised strength may still be the better choice if it machines faster, welds without preheat, or is stocked consistently by multiple suppliers in your region. Conversely, a high-performance alloy can become a liability if every batch arrives with different inclusion patterns or if the only approved source has a six-month lead time. Reviewing actual heat certificates, asking for reference applications, and testing a couple of lots before locking the design are practical steps that datasheets never mention but that make the difference between a smooth production run and recurring non-conformance reports.
It is also worth remembering that standards are minimum requirements, not quality targets. Two materials can both meet the same ASTM or ISO grade and still perform differently in a specific application because of grain size, residual stress, or surface condition. Rather than treating the datasheet as a final answer, treat it as a starting filter. Then narrow the field with your own corrosion coupons, fatigue specimens, or simple shop-floor trials that mimic the actual cutting, forming, and joining steps. This approach often reveals that the best material grade is not the one with the highest numbers on paper, but the one that degrades gracefully in your environment and fits your existing process capabilities.
FAQ
It comes down to magnetic strength, temperature stability, and mechanical integrity. The best options usually use neodymium-iron-boron grades with high coercivity, but the real difference is in how the magnet holds up under continuous duty cycles. If the coating or edge quality is poor, even a strong magnet will degrade quickly in a servo application.
Temperature rating often matters more than raw pull force. Servo motors can run hot, and standard neodymium magnets start losing performance above 80°C unless they're specially formulated. Look for grades with a maximum operating temperature at least 20% above your worst-case thermal scenario, and ask about irreversible loss curves rather than just a single number.
Samarium cobalt makes sense when the motor operates above 150°C or in chemically aggressive environments. It offers superior thermal stability and corrosion resistance, but it costs more and is mechanically brittle. For most precision servo applications, a well-chosen high-temperature neodymium grade delivers better value without sacrificing reliability.
Coatings fail when they're too thin, poorly bonded, or not matched to the operating environment. A standard nickel-copper-nickel coating handles normal conditions, but humid or salty air demands epoxy or even multilayer protection. The key is to inspect coating thickness and adhesion under thermal cycling, not just at room temperature.
Even small deviations in magnet thickness or chamfer can cause cogging torque, vibration, and inconsistent air gaps. High-performance servo motors need magnets with tight tolerances, often within ±0.05 mm, and consistent magnetic orientation. A supplier that can provide statistical process control data on dimensions is worth more than one that just quotes a lower price.
Look for evidence of application-specific testing, such as back-EMF waveform analysis, thermal shock cycling, and salt spray results. A knowledgeable supplier will ask about your rotor design, assembly method, and duty cycle before recommending a grade. If they immediately quote the cheapest N35 magnet without discussing coercivity or coating, that's a red flag.
Yes, especially if the motor can experience sudden load spikes or partial demagnetization fields from the stator. Higher coercivity, like an H or SH grade, provides a safety margin against demagnetization that extends service life. The cost difference is small compared to a field failure or a motor that loses torque over time.
Ask for full magnetic property reports per batch, not just sample certificates, along with dimension inspection data, coating thickness measurements, and pull-force or flux consistency tests. Also request thermal aging data at your motor's peak temperature. A reliable manufacturer will share this without hesitation and can trace every batch to raw material lots.
Conclusion
From the perspective of a servo motor magnets company, the first thing to check in high-performance magnets isn't the initial pull force or a spec-sheet number—it's how the magnet behaves once the motor is actually running. Heat and continuous load are the real test, so you need a grade that keeps its magnetic strength stable at elevated temperatures instead of fading after a few cycles. The coating matters just as much: in humid, salty, or chemically aggressive environments, a thin or poorly bonded coating allows corrosion to creep under the surface, which eventually lifts the magnet material and ruins the rotor balance. And don't assume every magnet on the rotor is identical; field consistency from pole to pole is what keeps torque ripple low and prevents one side of the motor from working harder than the other.
Air gap precision is another area where cheap magnets show their limits. Tight dimensional tolerances mean the gap between rotor and stator stays uniform, so you get predictable torque instead of hot spots and vibration. Over time, demagnetization resistance separates dependable magnets from ones that quietly lose power after months of rapid start-stop cycles or overloads. Finally, material grade choices should go beyond what the datasheet lists. A smart selection considers not only the nominal energy product but also how the coercivity, remanence, and temperature coefficients interact with your specific drive conditions. Small differences in these properties can make a large difference in servo accuracy and lifespan.
Contact Us
Contact Person: Kelvin Lo
Email: [email protected]
Tel/WhatsApp: 0769-88561131
Website: https://dawamagnetic.com/